 |
JSBSim Flight Dynamics Model 1.3.3 (16 Oct 2026)
An Open Source Flight Dynamics and Control Software Library in C++
|
|
JSBSim Flight Dynamics Model 1.3.3 (16 Oct 2026)
An Open Source Flight Dynamics and Control Software Library in C++
|
Utility class that handles power transmission in conjunction with FGRotor.
This class provides brake, clutch and free-wheel-unit (FWU) functionality for the rotor model. Also it is responsible for the RPM calculations.
When the engine is off the brake could be used to slow/hold down a spinning rotor. The maximum brake power is defined in the rotors' config file. (Right now there is no checking if the input is in the [0..1] range.)
The clutch operation is based on a heuristic approach. In the intermediate state the transfer is proportional to the clutch position. But equal RPM values are enforced on the thruster and rotor sides when approaching the closed state.
The FWU inhibits that the rotor is driving the engine. To do so, the code just predicts the upcoming FWU state based on current torque conditions.
Some engines won't work properly when the clutch is open. To keep them controllable some load must be provided on the engine side (EngineFriction, aka gear-loss). See the notes under 'Engine issues' in FGRotor.
The following properties are created (with x = your thruster number):
    propulsion/engine[x]/brake-ctrl-norm
    propulsion/engine[x]/free-wheel-transmission
    propulsion/engine[x]/clutch-ctrl-norm
Definition at line 108 of file FGTransmission.h.
#include <FGTransmission.h>
 Inheritance diagram for FGTransmission: Collaboration diagram for FGTransmission:
Public Member Functions | |
| FGTransmission (FGFDMExec *exec, int num, double dt) | |
| Constructor for FGTransmission. | |
| ~FGTransmission () | |
| Destructor for FGTransmission. | |
| void | Calculate (double EnginePower, double ThrusterTorque, double dt) |
| double | GetBrakeCtrlNorm () const |
| double | GetClutchCtrlNorm () const |
| double | GetEngineFriction () const |
| double | GetEngineMoment () const |
| double | GetEngineRPM () |
| double | GetFreeWheelTransmission () const |
| double | GetMaxBrakePower () const |
| double | GetThrusterMoment () const |
| double | GetThrusterRPM () |
| void | ResetToIC (void) |
| Reset the initial conditions. | |
| void | SetBrakeCtrlNorm (double x) |
| void | SetClutchCtrlNorm (double x) |
| void | SetEngineFriction (double x) |
| void | SetEngineMoment (double x) |
| void | SetEngineRPM (double x) |
| void | SetMaxBrakePower (double x) |
| void | SetThrusterMoment (double x) |
| void | SetThrusterRPM (double x) |
| Public Member Functions inherited from FGJSBBase | |
| FGJSBBase () | |
| Constructor for FGJSBBase. | |
| virtual | ~FGJSBBase () |
| Destructor for FGJSBBase. | |
Additional Inherited Members | |
| Public Types inherited from FGJSBBase | |
| enum | { eL = 1 , eM , eN } |
| Moments L, M, N. More... | |
| enum | { eP = 1 , eQ , eR } |
| Rates P, Q, R. More... | |
| enum | { eU = 1 , eV , eW } |
| Velocities U, V, W. More... | |
| enum | { eX = 1 , eY , eZ } |
| Positions X, Y, Z. More... | |
| enum | { ePhi = 1 , eTht , ePsi } |
| Euler angles Phi, Theta, Psi. More... | |
| enum | { eDrag = 1 , eSide , eLift } |
| Stability axis forces, Drag, Side force, Lift. More... | |
| enum | { eRoll = 1 , ePitch , eYaw } |
| Local frame orientation Roll, Pitch, Yaw. More... | |
| enum | { eNorth = 1 , eEast , eDown } |
| Local frame position North, East, Down. More... | |
| enum | { eLat = 1 , eLong , eRad } |
| Locations Radius, Latitude, Longitude. More... | |
| enum | { inNone = 0 , inDegrees , inRadians , inMeters , inFeet } |
| Conversion specifiers. More... | |
| Static Public Member Functions inherited from FGJSBBase | |
| static constexpr double | CelsiusToFahrenheit (double celsius) |
| Converts from degrees Celsius to degrees Fahrenheit. | |
| static constexpr double | CelsiusToKelvin (double celsius) |
| Converts from degrees Celsius to degrees Kelvin. | |
| static constexpr double | CelsiusToRankine (double celsius) |
| Converts from degrees Celsius to degrees Rankine. | |
| static constexpr double | Constrain (double min, double value, double max) |
| Constrain a value between a minimum and a maximum value. | |
| static bool | EqualToRoundoff (double a, double b) |
| Finite precision comparison. | |
| static bool | EqualToRoundoff (double a, float b) |
| Finite precision comparison. | |
| static bool | EqualToRoundoff (float a, double b) |
| Finite precision comparison. | |
| static bool | EqualToRoundoff (float a, float b) |
| Finite precision comparison. | |
| static constexpr double | FahrenheitToCelsius (double fahrenheit) |
| Converts from degrees Fahrenheit to degrees Celsius. | |
| static constexpr double | FeetToMeters (double measure) |
| Converts from feet to meters. | |
| static const std::string & | GetVersion (void) |
| Returns the version number of JSBSim. | |
| static constexpr double | KelvinToCelsius (double kelvin) |
| Converts from degrees Kelvin to degrees Celsius. | |
| static constexpr double | KelvinToFahrenheit (double kelvin) |
| Converts from degrees Kelvin to degrees Fahrenheit. | |
| static constexpr double | KelvinToRankine (double kelvin) |
| Converts from degrees Kelvin to degrees Rankine. | |
| static constexpr double | RankineToCelsius (double rankine) |
| Converts from degrees Rankine to degrees Celsius. | |
| static constexpr double | RankineToKelvin (double rankine) |
| Converts from degrees Rankine to degrees Kelvin. | |
| static constexpr double | sign (double num) |
| Static Public Attributes inherited from FGJSBBase | |
| static short | debug_lvl = 1 |
| Static Protected Member Functions inherited from FGJSBBase | |
| static std::string | CreateIndexedPropertyName (const std::string &Property, int index) |
| Static Protected Attributes inherited from FGJSBBase | |
| static constexpr double | degtorad = M_PI / 180. |
| static constexpr double | fpstokts = 1.0 / ktstofps |
| static constexpr double | fttom = 0.3048 |
| static constexpr double | hptoftlbssec = 550.0 |
| static constexpr double | in3tom3 = inchtoft*inchtoft*inchtoft/m3toft3 |
| static constexpr double | inchtoft = 1.0/12.0 |
| static constexpr double | inhgtopa = 3386.38 |
| static const std::string | JSBSim_version = JSBSIM_VERSION " " __DATE__ " " __TIME__ |
| static constexpr double | kgtolb = 2.20462 |
| static constexpr double | kgtoslug = 0.06852168 |
| static constexpr double | ktstofps = 1852./(3600*fttom) |
| static constexpr double | lbtoslug = 1.0/slugtolb |
| static constexpr double | m3toft3 = 1.0/(fttom*fttom*fttom) |
| static const std::string | needed_cfg_version = "2.0" |
| static constexpr double | psftoinhg = 0.014138 |
| static constexpr double | psftopa = 47.88 |
| static constexpr double | radtodeg = 180. / M_PI |
| static constexpr double | slugtolb = 32.174049 |
| Note that definition of lbtoslug by the inverse of slugtolb and not to a different constant you can also get from some tables will make lbtoslug*slugtolb == 1 up to the magnitude of roundoff. | |
| FGTransmission | ( | FGFDMExec * | exec, |
| int | num, | ||
| double | dt | ||
| ) |
Constructor for FGTransmission.
| exec | a pointer to the main executive object |
| num | the number of the thruster that uses this object |
| dt | simulation delta T |
Definition at line 53 of file FGTransmission.cpp.
Here is the call graph for this function:| ~FGTransmission | ( | ) |
| void Calculate | ( | double | EnginePower, |
| double | ThrusterTorque, | ||
| double | dt | ||
| ) |
Definition at line 88 of file FGTransmission.cpp.
|
inline |
Definition at line 140 of file FGTransmission.h.
|
inline |
Definition at line 142 of file FGTransmission.h.
|
inline |
Definition at line 128 of file FGTransmission.h.
|
inline |
Definition at line 130 of file FGTransmission.h.
|
inline |
Definition at line 136 of file FGTransmission.h.
|
inline |
Definition at line 134 of file FGTransmission.h.
|
inline |
Definition at line 126 of file FGTransmission.h.
|
inline |
Definition at line 132 of file FGTransmission.h.
|
inline |
Definition at line 138 of file FGTransmission.h.
| void ResetToIC | ( | void | ) |
Reset the initial conditions.
Definition at line 70 of file FGTransmission.cpp.
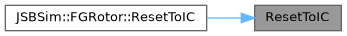
Here is the caller graph for this function:
|
inline |
Definition at line 141 of file FGTransmission.h.
|
inline |
Definition at line 143 of file FGTransmission.h.
|
inline |
Definition at line 127 of file FGTransmission.h.
|
inline |
Definition at line 129 of file FGTransmission.h.
|
inline |
Definition at line 135 of file FGTransmission.h.
|
inline |
Definition at line 125 of file FGTransmission.h.
|
inline |
Definition at line 131 of file FGTransmission.h.
|
inline |
Definition at line 137 of file FGTransmission.h.
 1.9.8