 |
JSBSim Flight Dynamics Model 1.3.3 (16 Oct 2026)
An Open Source Flight Dynamics and Control Software Library in C++
|
|
JSBSim Flight Dynamics Model 1.3.3 (16 Oct 2026)
An Open Source Flight Dynamics and Control Software Library in C++
|
Models weight, balance and moment of inertia information.
Maintains a vector of point masses. Sums the contribution of all, and provides this to FGPropagate. Loads the <mass_balance> section of the aircraft configuration file. There can be any number of <pointmasses>. Each can also have a shape which - if present - causes an associated moment of inertia to be calculated based on the shape. Note that a cylinder is solid, a tube is hollow, a ball is solid and a sphere is hollow.
The inertia tensor must be specified in the structural frame (x axis positive aft, y axis positive out of the right wing and z axis upward). The sign of the inertia cross products are optional by JSBSim. if negated_crossproduct_inertia == "true", then define: ixy = -integral( x * y * dm ), ixz = -integral( x * z * dm ), iyz = -integral( y * z * dm ). else if negated_crossproduct_inertia == "false", then define: ixy = integral( x * y * dm ), ixz = integral( x * z * dm ), iyz = integral( y * z * dm ). default is negated_crossproduct_inertia = "true". We strongly recommend defining negated_crossproduct_inertia = "false", which is consistent with the specifications in the field of flight dynamics.
@see Stevens and Lewis, "Flight Control & Simulation"
@see Bernard Etkin, " Dynamics Of Atmosferic Flight"
@see https://en.wikipedia.org/wiki/Moment_of_inertia#Inertia_tensor
@see https://www.mathworks.com/help/physmod/sm/ug/specify-custom-inertia.html
Definition at line 124 of file FGMassBalance.h.
#include <FGMassBalance.h>
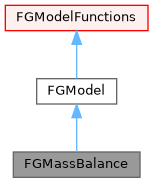
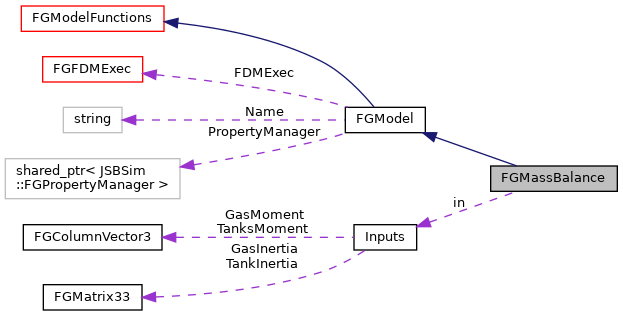
 Inheritance diagram for FGMassBalance: Collaboration diagram for FGMassBalance:
Classes | |
| struct | Inputs |
Public Member Functions | |
| FGMassBalance (FGFDMExec *) | |
| void | AddPointMass (Element *el) |
| double | GetDeltaXYZcg (int axis) const |
| const FGColumnVector3 & | GetDeltaXYZcg (void) const |
| double | GetEmptyWeight (void) const |
| const FGMatrix33 & | GetJ (void) const |
| Returns the inertia matrix expressed in the body frame. | |
| const FGMatrix33 & | GetJinv (void) const |
| Returns the inverse of the inertia matrix expressed in the body frame. | |
| double | GetMass (void) const |
| void | GetMassPropertiesReport (int i) |
| FGMatrix33 | GetPointmassInertia (double mass_sl, const FGColumnVector3 &r) const |
| Computes the inertia contribution of a pointmass. | |
| const FGColumnVector3 & | GetPointMassMoment (void) |
| double | GetTotalPointMassWeight (void) const |
| double | GetWeight (void) const |
| double | GetXYZcg (int axis) const |
| const FGColumnVector3 & | GetXYZcg (void) const |
| Returns the coordinates of the center of gravity expressed in the structural frame. | |
| bool | InitModel (void) override |
| bool | Load (Element *el) override |
| bool | Run (bool Holding) override |
| Runs the Mass Balance model; called by the Executive Can pass in a value indicating if the executive is directing the simulation to Hold. | |
| void | SetAircraftBaseInertias (const FGMatrix33 &BaseJ) |
| void | SetBaseCG (const FGColumnVector3 &CG) |
| void | SetEmptyWeight (double EW) |
| FGColumnVector3 | StructuralToBody (const FGColumnVector3 &r) const |
| Conversion from the structural frame to the body frame. | |
| Public Member Functions inherited from FGModel | |
| FGModel (FGFDMExec *, const std::string &name) | |
| Constructor. | |
| ~FGModel () override | |
| Destructor. | |
| virtual SGPath | FindFullPathName (const SGPath &path) const |
| FGFDMExec * | GetExec (void) const |
| const std::string & | GetName (void) const |
| unsigned int | GetRate (void) const |
| Get the output rate for the model in frames. | |
| bool | InitModel (void) override |
| void | SetPropertyManager (std::shared_ptr< FGPropertyManager > fgpm) |
| void | SetRate (unsigned int tt) |
| Set the ouput rate for the model in frames. | |
| Public Member Functions inherited from FGModelFunctions | |
| std::string | GetFunctionStrings (const std::string &delimeter) const |
| Gets the strings for the current set of functions. | |
| std::string | GetFunctionValues (const std::string &delimeter) const |
| Gets the function values. | |
| std::shared_ptr< FGFunction > | GetPreFunction (const std::string &name) |
| Get one of the "pre" function. | |
| bool | Load (Element *el, FGFDMExec *fdmex, std::string prefix="") |
| void | PostLoad (Element *el, FGFDMExec *fdmex, std::string prefix="") |
| void | PreLoad (Element *el, FGFDMExec *fdmex, std::string prefix="") |
| void | RunPostFunctions (void) |
| void | RunPreFunctions (void) |
| Public Member Functions inherited from FGJSBBase | |
| FGJSBBase () | |
| Constructor for FGJSBBase. | |
| virtual | ~FGJSBBase () |
| Destructor for FGJSBBase. | |
Public Attributes | |
| struct JSBSim::FGMassBalance::Inputs | in |
Additional Inherited Members | |
| Public Types inherited from FGJSBBase | |
| enum | { eL = 1 , eM , eN } |
| Moments L, M, N. More... | |
| enum | { eP = 1 , eQ , eR } |
| Rates P, Q, R. More... | |
| enum | { eU = 1 , eV , eW } |
| Velocities U, V, W. More... | |
| enum | { eX = 1 , eY , eZ } |
| Positions X, Y, Z. More... | |
| enum | { ePhi = 1 , eTht , ePsi } |
| Euler angles Phi, Theta, Psi. More... | |
| enum | { eDrag = 1 , eSide , eLift } |
| Stability axis forces, Drag, Side force, Lift. More... | |
| enum | { eRoll = 1 , ePitch , eYaw } |
| Local frame orientation Roll, Pitch, Yaw. More... | |
| enum | { eNorth = 1 , eEast , eDown } |
| Local frame position North, East, Down. More... | |
| enum | { eLat = 1 , eLong , eRad } |
| Locations Radius, Latitude, Longitude. More... | |
| enum | { inNone = 0 , inDegrees , inRadians , inMeters , inFeet } |
| Conversion specifiers. More... | |
| Static Public Member Functions inherited from FGJSBBase | |
| static constexpr double | CelsiusToFahrenheit (double celsius) |
| Converts from degrees Celsius to degrees Fahrenheit. | |
| static constexpr double | CelsiusToKelvin (double celsius) |
| Converts from degrees Celsius to degrees Kelvin. | |
| static constexpr double | CelsiusToRankine (double celsius) |
| Converts from degrees Celsius to degrees Rankine. | |
| static constexpr double | Constrain (double min, double value, double max) |
| Constrain a value between a minimum and a maximum value. | |
| static bool | EqualToRoundoff (double a, double b) |
| Finite precision comparison. | |
| static bool | EqualToRoundoff (double a, float b) |
| Finite precision comparison. | |
| static bool | EqualToRoundoff (float a, double b) |
| Finite precision comparison. | |
| static bool | EqualToRoundoff (float a, float b) |
| Finite precision comparison. | |
| static constexpr double | FahrenheitToCelsius (double fahrenheit) |
| Converts from degrees Fahrenheit to degrees Celsius. | |
| static constexpr double | FeetToMeters (double measure) |
| Converts from feet to meters. | |
| static const std::string & | GetVersion (void) |
| Returns the version number of JSBSim. | |
| static constexpr double | KelvinToCelsius (double kelvin) |
| Converts from degrees Kelvin to degrees Celsius. | |
| static constexpr double | KelvinToFahrenheit (double kelvin) |
| Converts from degrees Kelvin to degrees Fahrenheit. | |
| static constexpr double | KelvinToRankine (double kelvin) |
| Converts from degrees Kelvin to degrees Rankine. | |
| static constexpr double | RankineToCelsius (double rankine) |
| Converts from degrees Rankine to degrees Celsius. | |
| static constexpr double | RankineToKelvin (double rankine) |
| Converts from degrees Rankine to degrees Kelvin. | |
| static constexpr double | sign (double num) |
| Static Public Attributes inherited from FGJSBBase | |
| static short | debug_lvl = 1 |
| Protected Member Functions inherited from FGModel | |
| bool | Upload (Element *el, bool preLoad) |
| Uploads this model in memory. | |
| Static Protected Member Functions inherited from FGJSBBase | |
| static std::string | CreateIndexedPropertyName (const std::string &Property, int index) |
| Protected Attributes inherited from FGModel | |
| bool | enabled = true |
| unsigned int | exe_ctr |
| FGFDMExec * | FDMExec |
| std::string | Name |
| std::shared_ptr< FGPropertyManager > | PropertyManager |
| unsigned int | rate |
| Protected Attributes inherited from FGModelFunctions | |
| FGPropertyReader | LocalProperties |
| std::vector< std::shared_ptr< FGFunction > > | PostFunctions |
| std::vector< std::shared_ptr< FGFunction > > | PreFunctions |
| Static Protected Attributes inherited from FGJSBBase | |
| static constexpr double | degtorad = M_PI / 180. |
| static constexpr double | fpstokts = 1.0 / ktstofps |
| static constexpr double | fttom = 0.3048 |
| static constexpr double | hptoftlbssec = 550.0 |
| static constexpr double | in3tom3 = inchtoft*inchtoft*inchtoft/m3toft3 |
| static constexpr double | inchtoft = 1.0/12.0 |
| static constexpr double | inhgtopa = 3386.38 |
| static const std::string | JSBSim_version = JSBSIM_VERSION " " __DATE__ " " __TIME__ |
| static constexpr double | kgtolb = 2.20462 |
| static constexpr double | kgtoslug = 0.06852168 |
| static constexpr double | ktstofps = 1852./(3600*fttom) |
| static constexpr double | lbtoslug = 1.0/slugtolb |
| static constexpr double | m3toft3 = 1.0/(fttom*fttom*fttom) |
| static const std::string | needed_cfg_version = "2.0" |
| static constexpr double | psftoinhg = 0.014138 |
| static constexpr double | psftopa = 47.88 |
| static constexpr double | radtodeg = 180. / M_PI |
| static constexpr double | slugtolb = 32.174049 |
| Note that definition of lbtoslug by the inverse of slugtolb and not to a different constant you can also get from some tables will make lbtoslug*slugtolb == 1 up to the magnitude of roundoff. | |
|
explicit |
Definition at line 59 of file FGMassBalance.cpp.
| ~FGMassBalance | ( | ) |
Definition at line 81 of file FGMassBalance.cpp.
| void AddPointMass | ( | Element * | el | ) |
Definition at line 269 of file FGMassBalance.cpp.
|
inline |
Definition at line 151 of file FGMassBalance.h.
|
inline |
Definition at line 150 of file FGMassBalance.h.
|
inline |
Definition at line 145 of file FGMassBalance.h.
|
inline |
Returns the inertia matrix expressed in the body frame.
Definition at line 195 of file FGMassBalance.h.
|
inline |
Returns the inverse of the inertia matrix expressed in the body frame.
Definition at line 197 of file FGMassBalance.h.
|
inline |
Definition at line 143 of file FGMassBalance.h.
| void GetMassPropertiesReport | ( | int | i | ) |
Definition at line 439 of file FGMassBalance.cpp.
|
inline |
Computes the inertia contribution of a pointmass.
Computes and returns the inertia matrix of a pointmass of mass slugs at the given vector r in the structural frame. The units should be for the mass in slug and the vector in the structural frame as usual in inches.
| mass_sl | the mass of this single pointmass given in slugs |
| r | the location of this single pointmass in the structural frame |
Definition at line 161 of file FGMassBalance.h.
| const FGColumnVector3 & GetPointMassMoment | ( | void | ) |
Definition at line 337 of file FGMassBalance.cpp.
| double GetTotalPointMassWeight | ( | void | ) | const |
Definition at line 325 of file FGMassBalance.cpp.
|
inline |
Definition at line 144 of file FGMassBalance.h.
|
inline |
Definition at line 149 of file FGMassBalance.h.
|
inline |
Returns the coordinates of the center of gravity expressed in the structural frame.
Definition at line 148 of file FGMassBalance.h.
|
overridevirtual |
Reimplemented from FGModelFunctions.
Definition at line 90 of file FGMassBalance.cpp.
|
overridevirtual |
Reimplemented from FGModel.
Definition at line 135 of file FGMassBalance.cpp.
|
overridevirtual |
Runs the Mass Balance model; called by the Executive Can pass in a value indicating if the executive is directing the simulation to Hold.
| Holding | if true, the executive has been directed to hold the sim from advancing time. Some models may ignore this flag, such as the Input model, which may need to be active to listen on a socket for the "Resume" command to be given. |
Reimplemented from FGModel.
Definition at line 184 of file FGMassBalance.cpp.
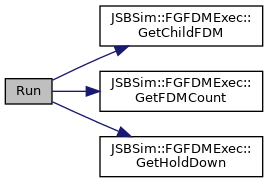
Here is the call graph for this function:
|
inline |
Definition at line 198 of file FGMassBalance.h.
|
inline |
Definition at line 188 of file FGMassBalance.h.
|
inline |
Definition at line 187 of file FGMassBalance.h.
| FGColumnVector3 StructuralToBody | ( | const FGColumnVector3 & | r | ) | const |
Conversion from the structural frame to the body frame.
Converts the location given in the structural frame coordinate system to the body frame. The units of the structural frame are assumed to be in inches. The unit of the result is in ft.
| r | vector coordinate in the structural reference frame (X positive aft, measurements in inches). |
Definition at line 365 of file FGMassBalance.cpp.
 1.9.8